02 / 05
A few things I’ve built.
04 / PROJECTS
PLANNING
READY
00:40
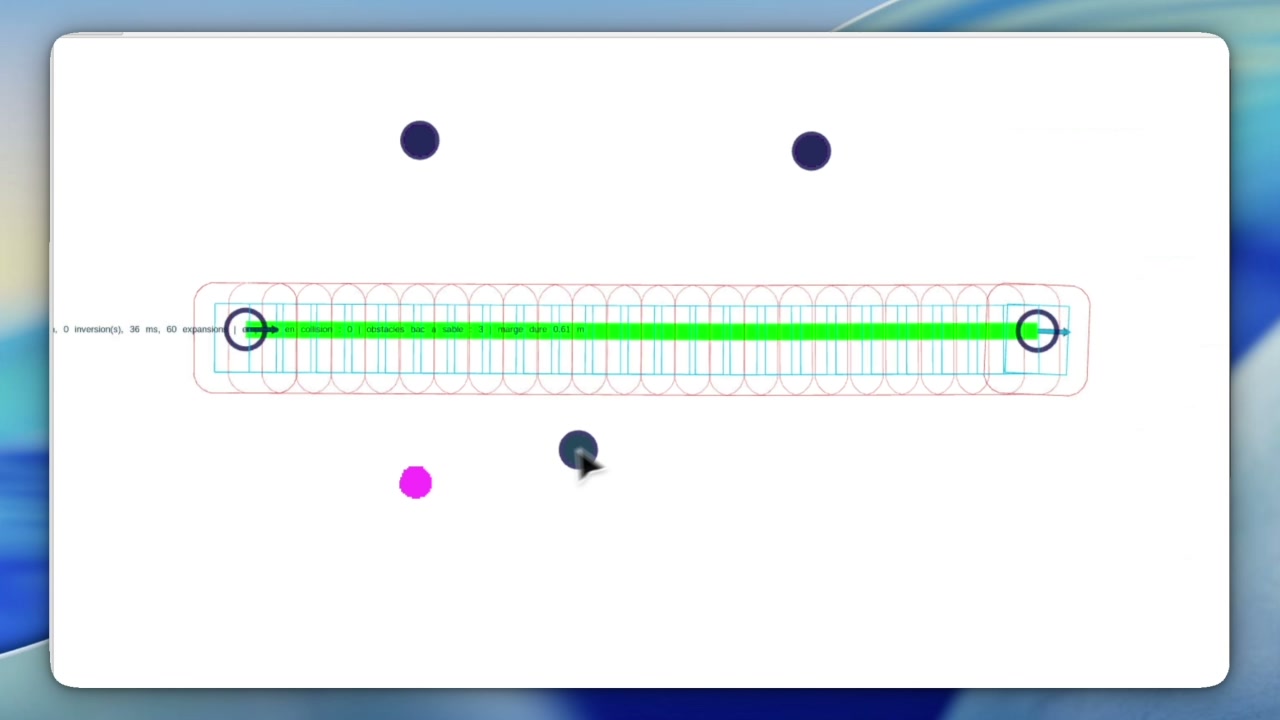
Add the corresponding video file to site/assets/videos/ to activate this demonstration.
SE(2) Planner
Plan collision-free motion for differential-drive robots with asymmetric footprints.
01 / 05
From software to the field
Navigation, control, sensor fusion, automation, and fleet management: I work on both the robots and the software around them. I also help teams define requirements and organize development.
03 / 05
Tools I work with
- ROS 2

- Gazebo
- C++

- Python

- Linux

- Git

Automation: CODESYS, SoftPLC, and Structured Text. DevOps: Docker and CI/CD. AI-assisted development.
04 / 05
Research and publications
Two more papers
05 / 05